SKU: OT2065-A44 Artikelnummer: NA272 EAN: 8720589817388
Egenskaper:
1. Standbykontroll för att spara ström.
2. CW / CCW / kort broms / stopp motorstyrningslägen.
3. Inbyggd termisk avstängningskrets och lågspänningsdetekteringskrets.
Beskrivning:
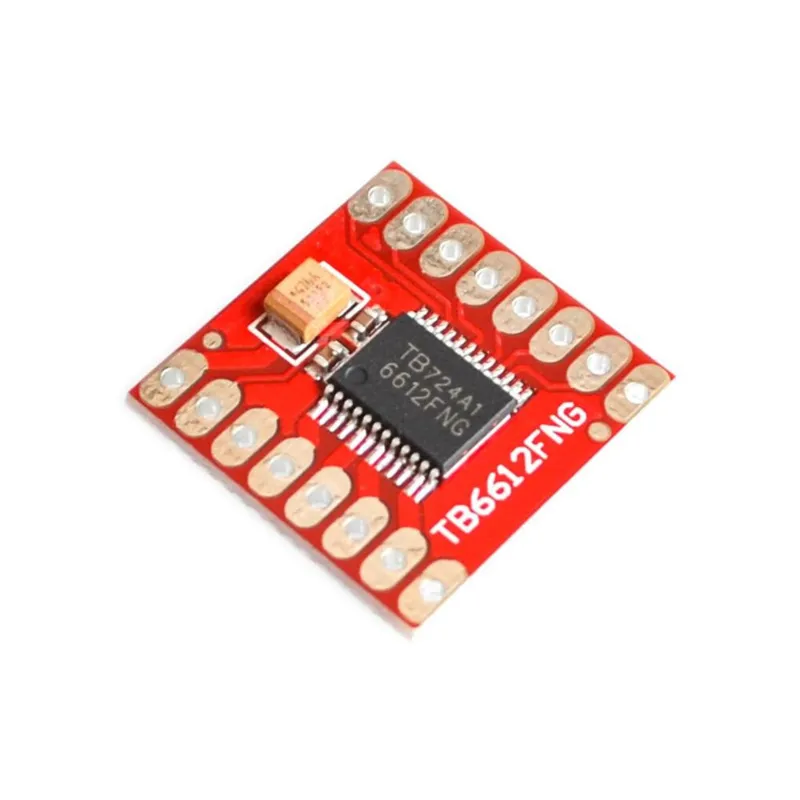
TB6612FNG-motordrivaren kan styra upp till två DC-motorer med en konstant ström på 1,2 A (3,2 A topp). Två insignaler (IN1 och IN2) kan användas för att styra motorn i ett av fyra funktionslägen: medurs, moturs, kort broms och stopp. De två motorutgångarna (A och B) kan styras separat, hastigheten för varje motor regleras via en PWM-insignal med en frekvens upp till 100 kHz. STBY-pinnen måste dras hög för att väcka motorn ur standbyläge.
Logisk matningsspänning (VCC) kan ligga i intervallet 2,7-5,5 VDC, medan motorförsörjningen (VM) är begränsad till en maximal spänning på 15 VDC. Utgångsströmmen är nominellt upp till 1,2 A per kanal (eller upp till 3,2 A för en kort, enstaka puls).
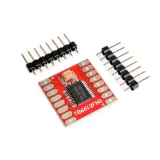
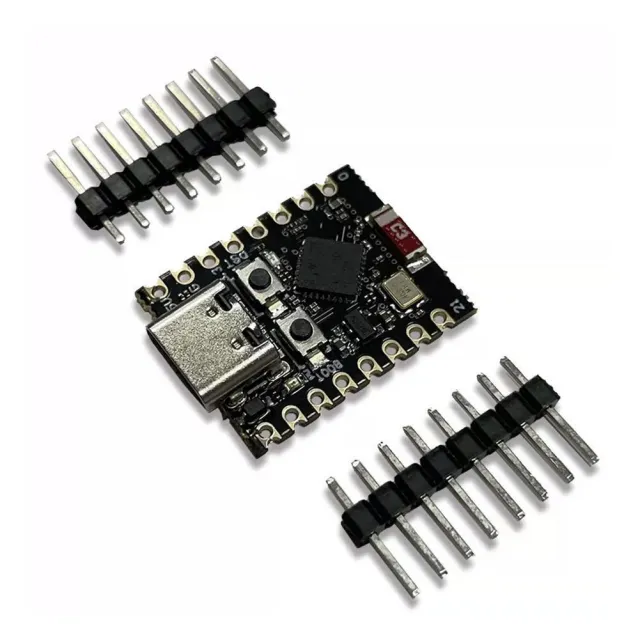
Kortet levereras med alla komponenter som visas inklusive headerpinnarna.
Specifikationer:
Matningsspänning: VM = 15V max, VCC = 2,7-5,5V
Utgångsström: Iout = 1,2 A (genomsnitt) / 3,2 A (topp)
Mått
Längd: 2cm
Bredd: 2cm
Höjd: 0,3cm
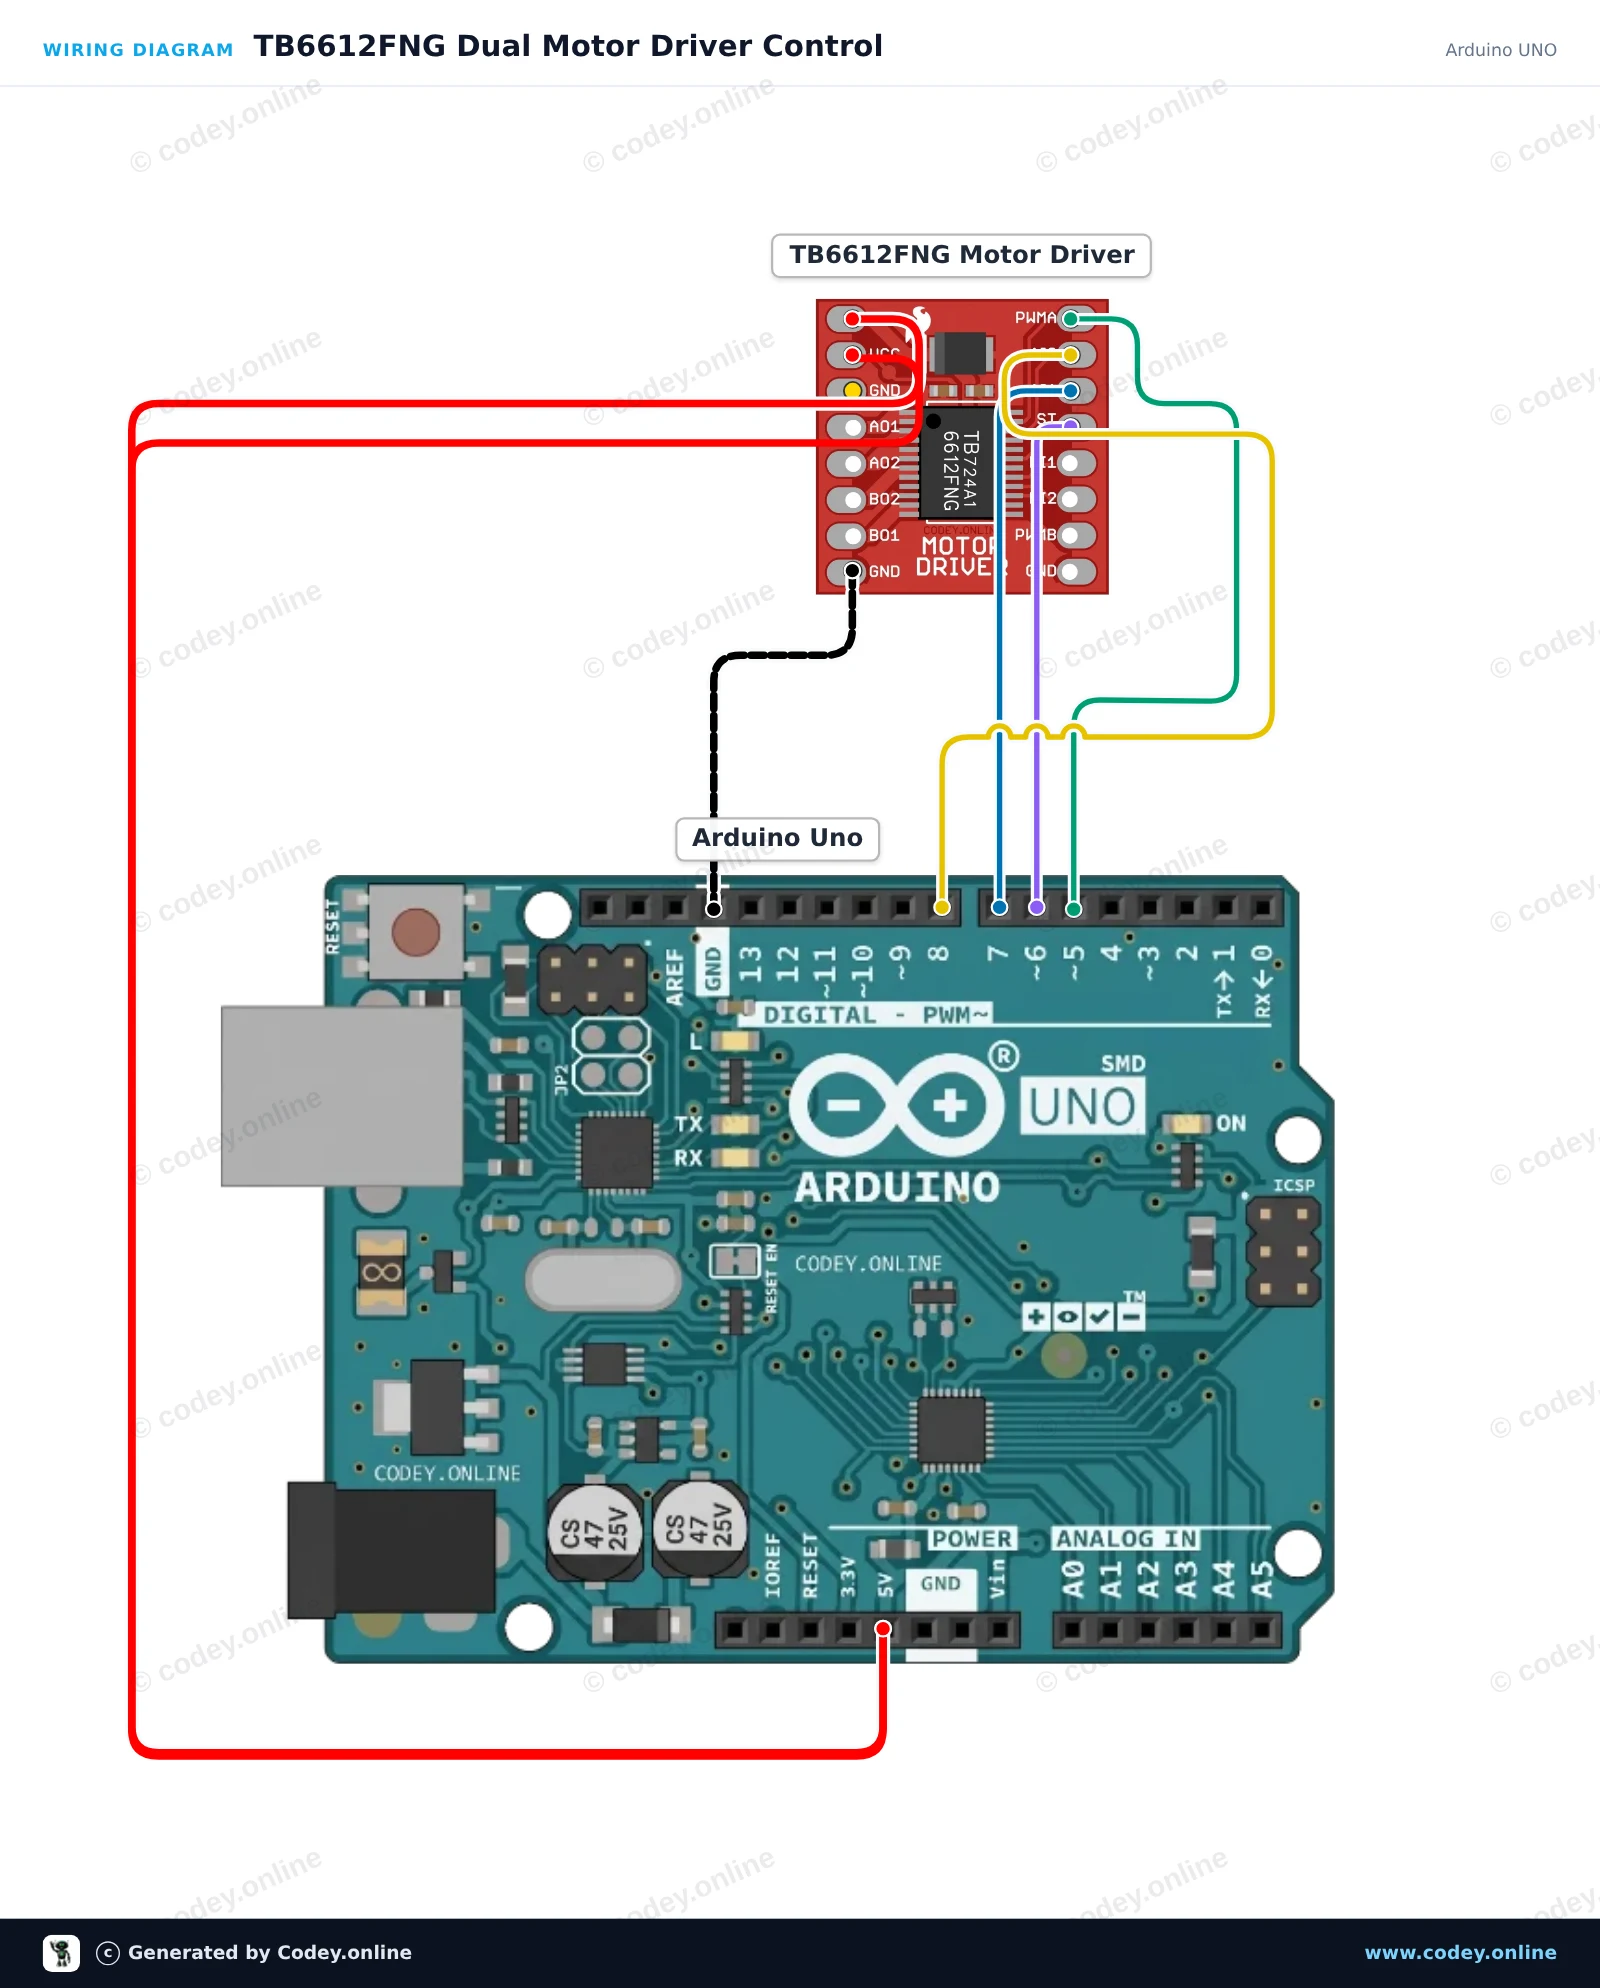
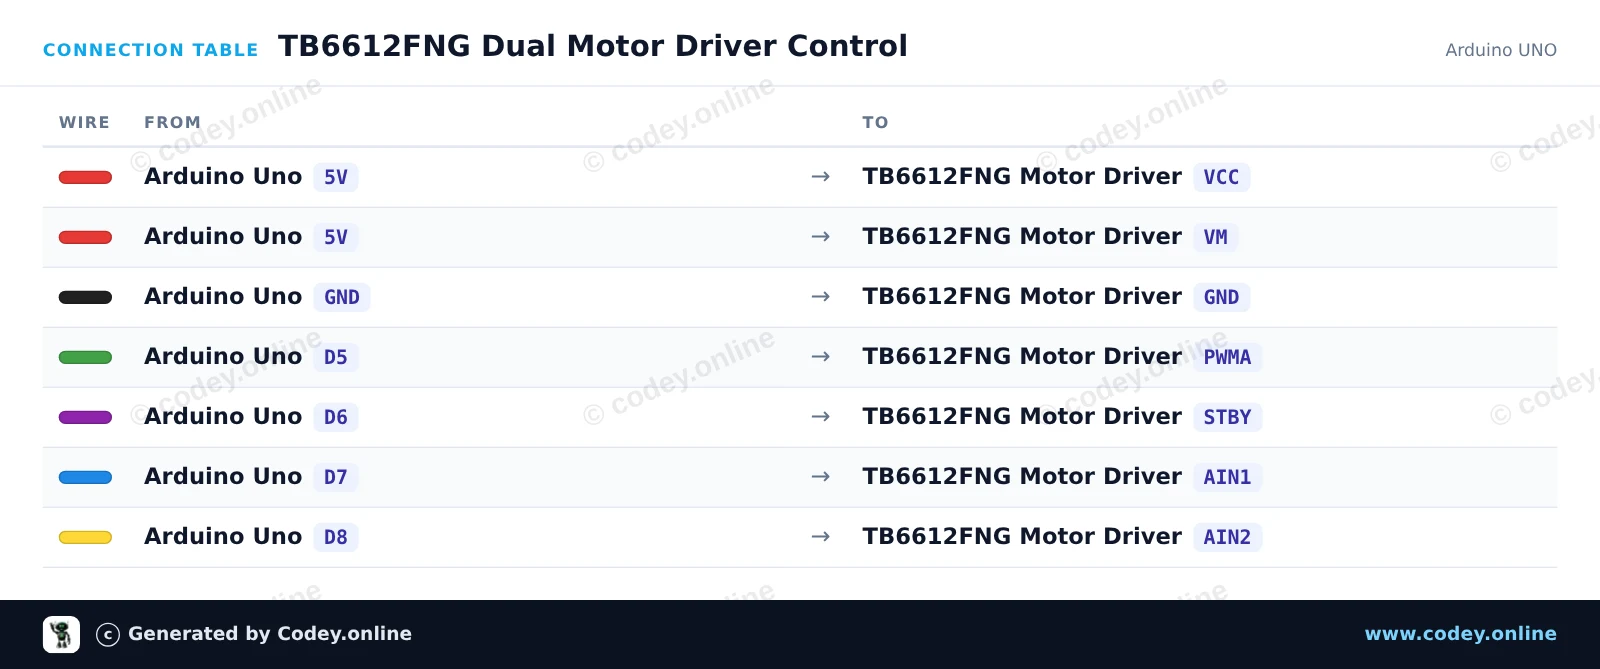
Så här kopplar du Motorstyrmodul TB6612FNG för Arduino till en Arduino UNO eller ESP32, med ett exempelsketch som du kan ladda upp direkt.
This project controls a DC motor channel using the dual H-bridge TB6612FNG driver. The sketch enables the driver via the standby pin and alternates running the motor forward, stopping, and running in reverse with PWM speed control. Open the Serial Monitor at 115200 baud to observe the operating status.
/*
 * ==================================================================
 *  Generated by Codey.online  —  https://www.codey.online
 * ==================================================================
 *  Project   : TB6612FNG Dual Motor Driver Control
 *  Board     : Arduino UNO (arduino:avr:uno)
 *  Parts     : TB6612FNG Motor Driver
 *  Libraries : none (built-in)
 *
 *  Codey Online is an AI-powered browser IDE for Arduino and ESP32.
 *  Describe your project and Codey writes the code, draws the wiring
 *  diagram and uploads it to your board, straight from the browser.
 *  This code is free to use, modify and share, without warranty.
 * ==================================================================
 */

const int PIN_PWMA = 5;
const int PIN_STBY = 6;
const int PIN_AIN1 = 7;
const int PIN_AIN2 = 8;

void setup() {
  Serial.begin(115200);

  pinMode(PIN_PWMA, OUTPUT);
  pinMode(PIN_STBY, OUTPUT);
  pinMode(PIN_AIN1, OUTPUT);
  pinMode(PIN_AIN2, OUTPUT);

  // Take driver out of standby mode
  digitalWrite(PIN_STBY, HIGH);

  Serial.println(F("TB6612FNG Motor Driver Initialized"));
}

void driveMotorA(bool forward, int speed) {
  speed = constrain(speed, 0, 255);

  if (forward) {
    digitalWrite(PIN_AIN1, HIGH);
    digitalWrite(PIN_AIN2, LOW);
    Serial.print(F("Motor Forward at speed: "));
  } else {
    digitalWrite(PIN_AIN1, LOW);
    digitalWrite(PIN_AIN2, HIGH);
    Serial.print(F("Motor Reverse at speed: "));
  }

  analogWrite(PIN_PWMA, speed);
  Serial.println(speed);
}

void stopMotorA() {
  analogWrite(PIN_PWMA, 0);
  digitalWrite(PIN_AIN1, LOW);
  digitalWrite(PIN_AIN2, LOW);
  Serial.println(F("Motor Stopped"));
}

void loop() {
  // Drive forward at speed 200
  driveMotorA(true, 200);
  delay(2000);

  // Stop
  stopMotorA();
  delay(1000);

  // Drive reverse at speed 200
  driveMotorA(false, 200);
  delay(2000);

  // Stop
  stopMotorA();
  delay(1000);
}Wiring diagram and example code generated by Codey.online — https://www.codey.online
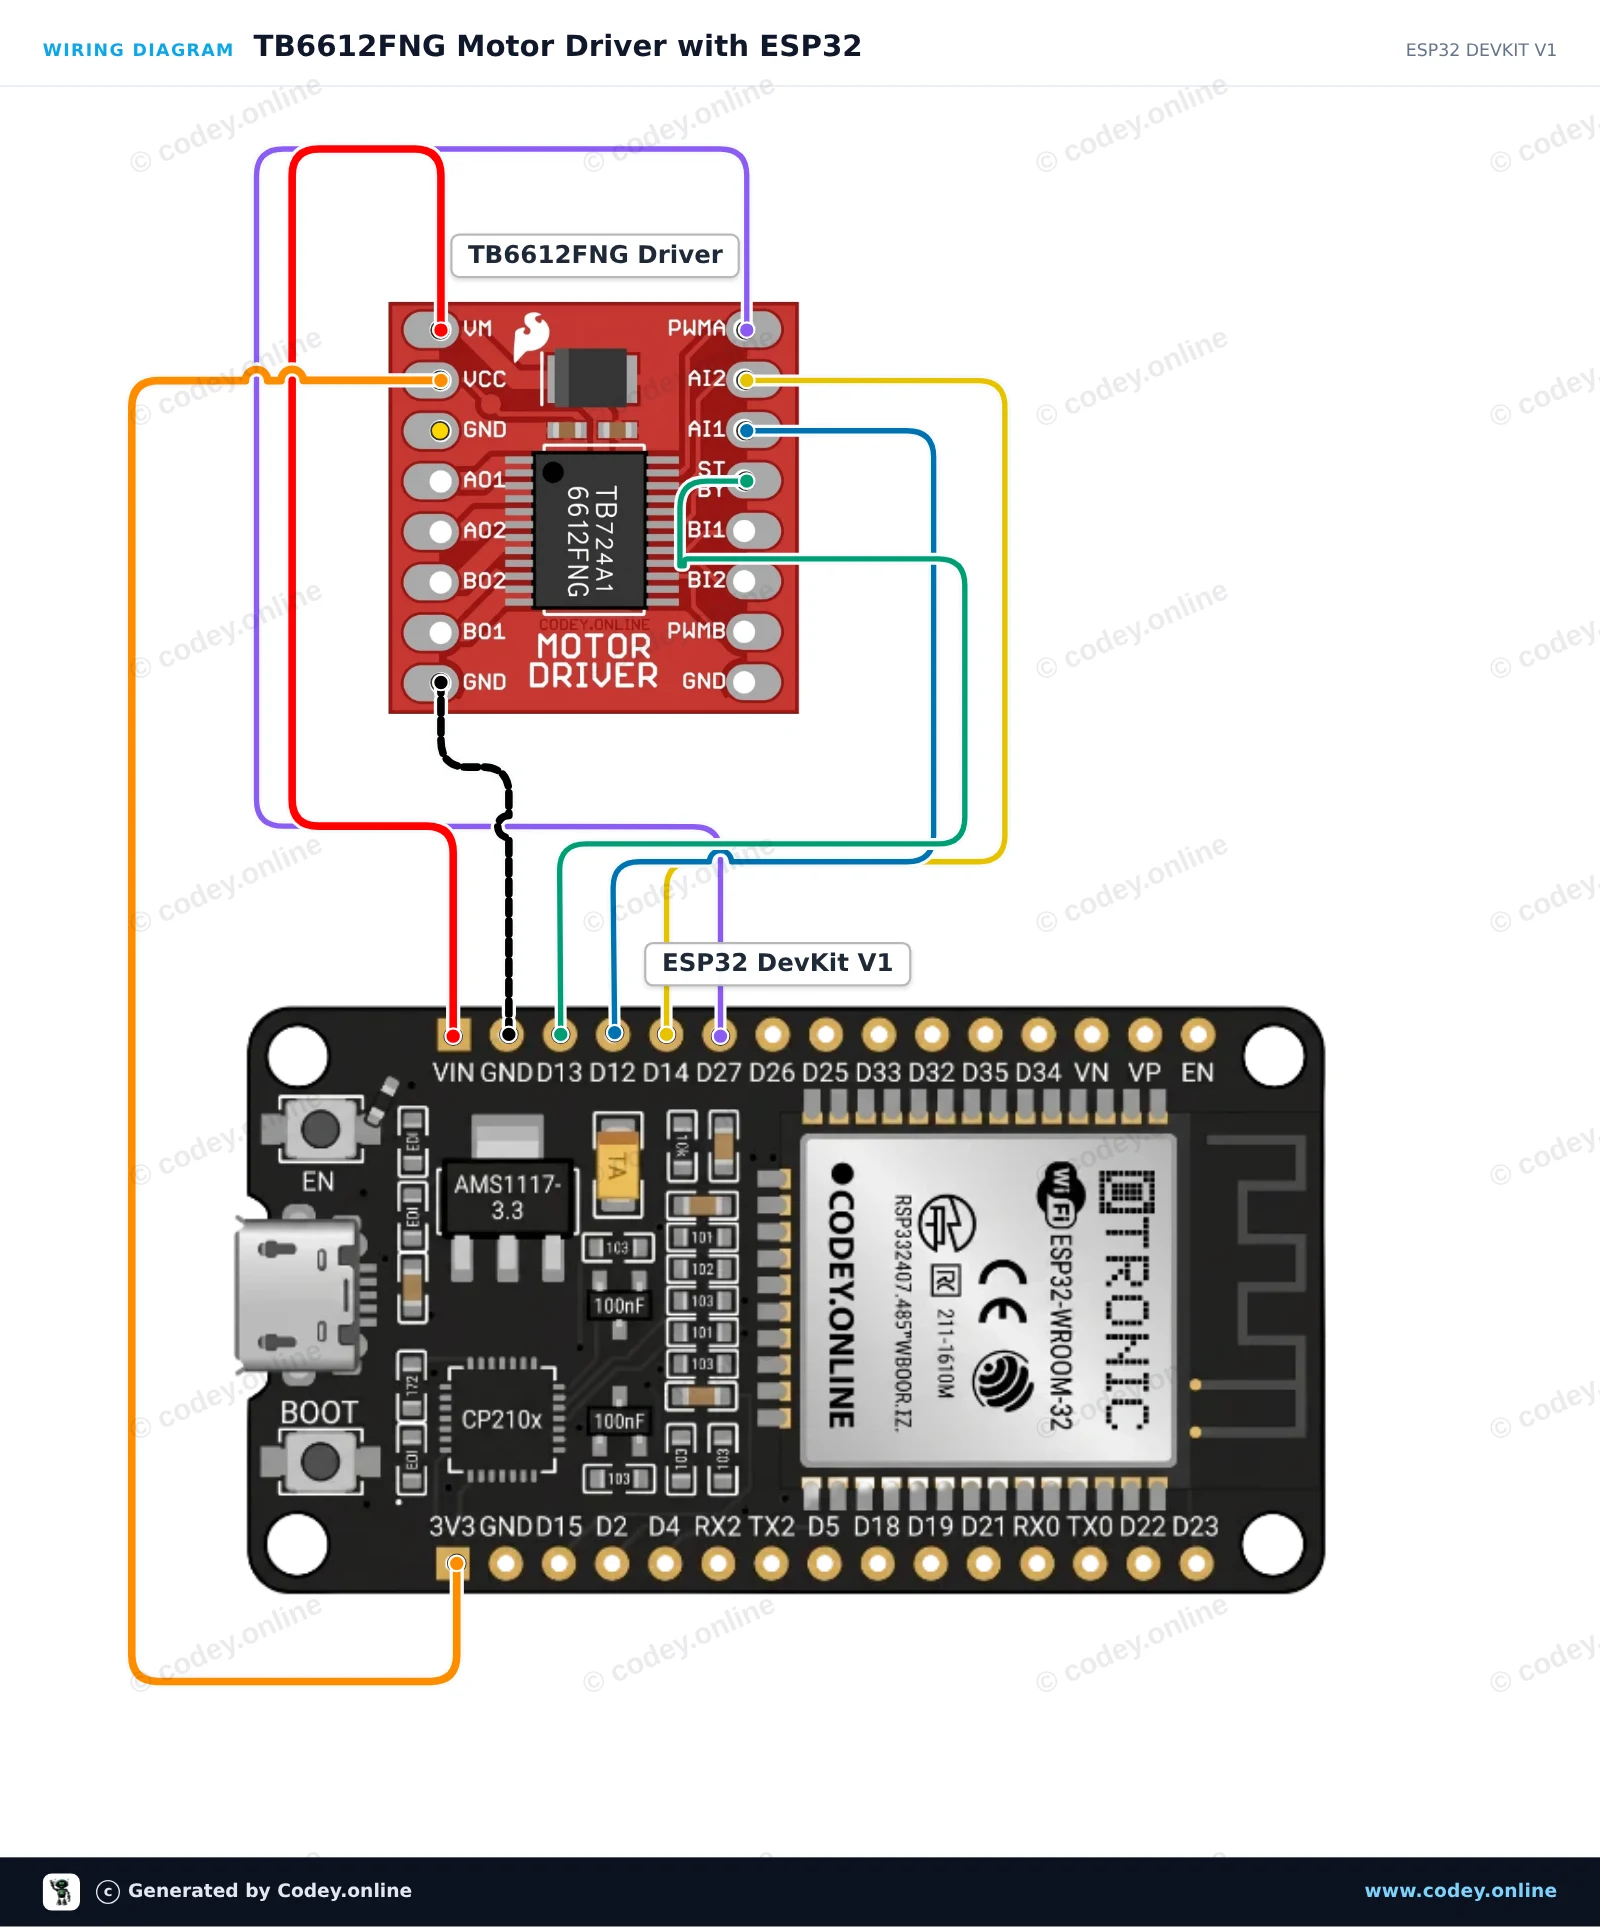
This project demonstrates controlling a DC motor using the TB6612FNG dual H-bridge motor driver and an ESP32. The sketch enables the driver via the STBY pin and cycles motor channel A through forward rotation, deceleration, reverse rotation, and braking. Open the Serial Monitor at 115200 baud to view the current motor state and speed.
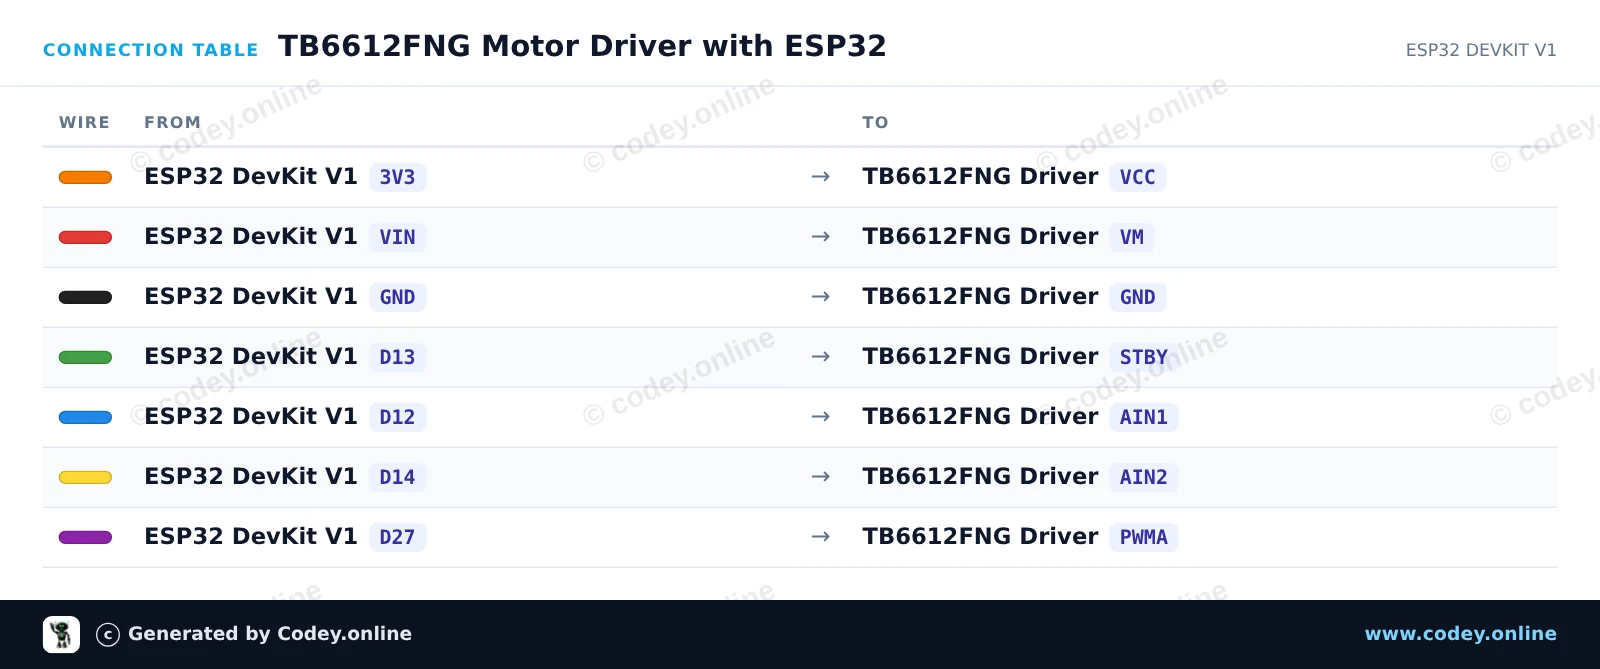
/*
 * ==================================================================
 *  Generated by Codey.online  —  https://www.codey.online
 * ==================================================================
 *  Project   : TB6612FNG Motor Driver with ESP32
 *  Board     : ESP32 DEVKIT V1 (esp32:esp32:esp32doit-devkit-v1)
 *  Parts     : TB6612FNG Motor Driver
 *  Libraries : none (built-in)
 *
 *  Codey Online is an AI-powered browser IDE for Arduino and ESP32.
 *  Describe your project and Codey writes the code, draws the wiring
 *  diagram and uploads it to your board, straight from the browser.
 *  This code is free to use, modify and share, without warranty.
 * ==================================================================
 */

// TB6612FNG Dual H-Bridge Motor Driver Demo on ESP32

const int PIN_STBY = 13;
const int PIN_AIN1 = 12;
const int PIN_AIN2 = 14;
const int PIN_PWMA = 27;

void setup() {
  Serial.begin(115200);

  pinMode(PIN_STBY, OUTPUT);
  pinMode(PIN_AIN1, OUTPUT);
  pinMode(PIN_AIN2, OUTPUT);
  pinMode(PIN_PWMA, OUTPUT);

  // Enable driver
  digitalWrite(PIN_STBY, HIGH);
  Serial.println("TB6612FNG Motor Driver Initialized");
}

void driveMotor(bool forward, int speed) {
  if (forward) {
    digitalWrite(PIN_AIN1, HIGH);
    digitalWrite(PIN_AIN2, LOW);
  } else {
    digitalWrite(PIN_AIN1, LOW);
    digitalWrite(PIN_AIN2, HIGH);
  }
  analogWrite(PIN_PWMA, constrain(speed, 0, 255));
}

void stopMotor() {
  digitalWrite(PIN_AIN1, LOW);
  digitalWrite(PIN_AIN2, LOW);
  analogWrite(PIN_PWMA, 0);
}

void loop() {
  // Forward acceleration
  Serial.println("Motor Forward: Accelerating");
  for (int spd = 50; spd <= 255; spd += 25) {
    driveMotor(true, spd);
    delay(150);
  }
  delay(1000);

  // Stop
  Serial.println("Motor Stop");
  stopMotor();
  delay(1000);

  // Reverse acceleration
  Serial.println("Motor Reverse: Accelerating");
  for (int spd = 50; spd <= 255; spd += 25) {
    driveMotor(false, spd);
    delay(150);
  }
  delay(1000);

  // Stop
  Serial.println("Motor Stop");
  stopMotor();
  delay(2000);
}Wiring diagram and example code generated by Codey.online — https://www.codey.online




 English
 Nederlands
 Frans
 Deutsch
 Italiano
 Español
 Suomi
 Polski
 Dansk
 Ελληνικά
 Български
 Čeština
 Hrvatski
 Aileen